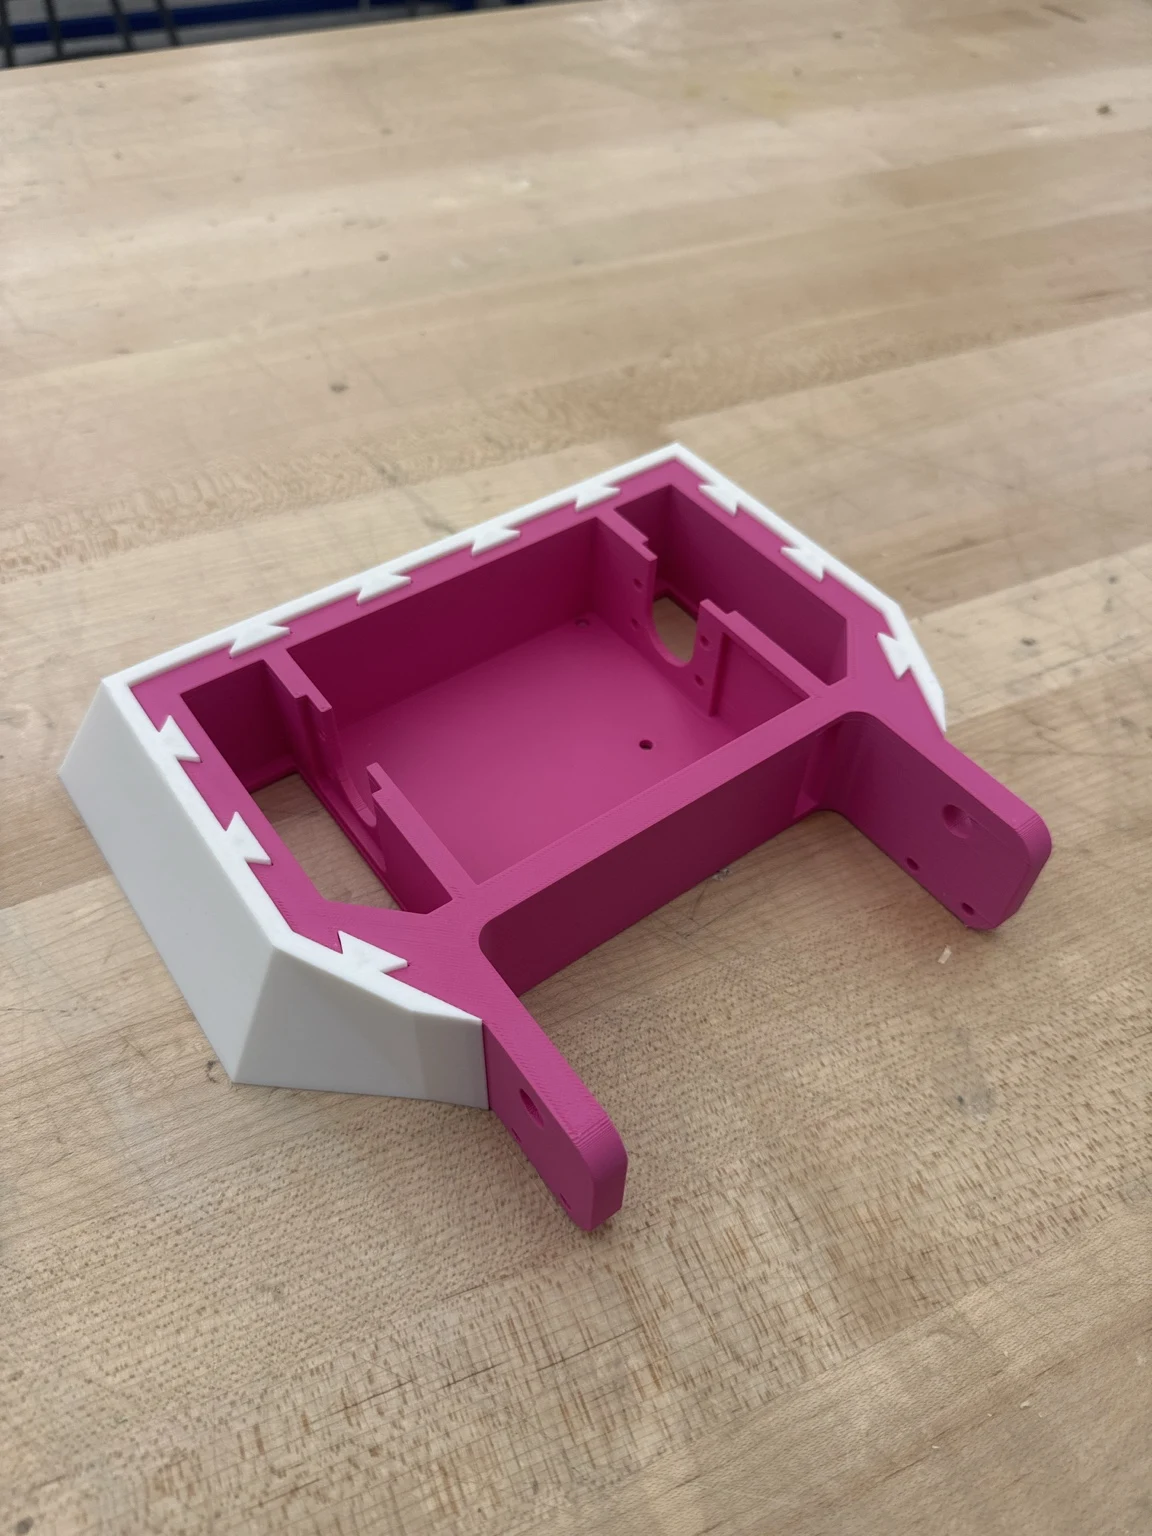
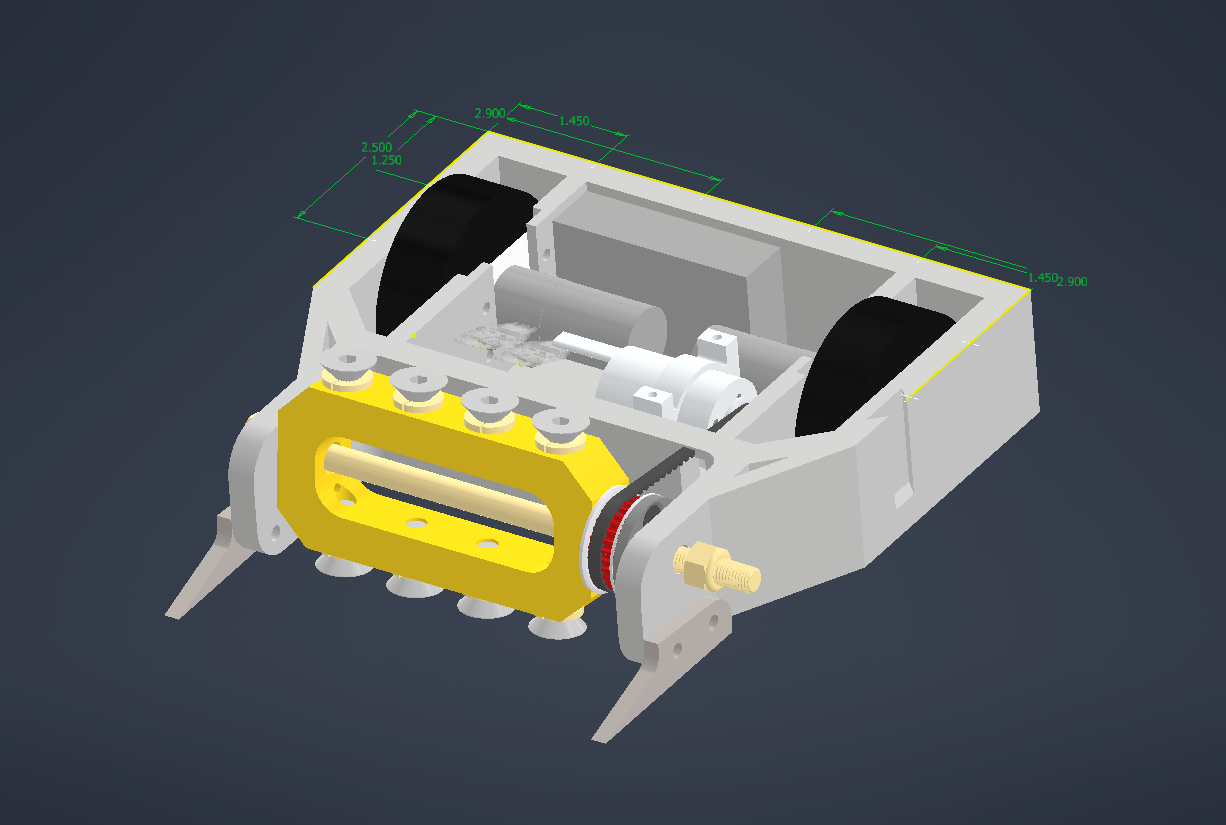
Shrike
3 lb · BeetleweightA custom chassis built around a beater-bar assembly, with carbon-fiber-reinforced nylon construction and a polycarbonate top. Designed by students at Embry-Riddle.
View Shrike’s profile (opens in a new tab)In development
Developing a collegiate combat robotics program at Embry-Riddle.
I founded the Embry-Riddle ASME Combat Robotics program and serve as project lead. My responsibilities include project planning, recruitment, sponsorship outreach, and organizing the design work needed to move a collegiate team forward. I manage the team’s work on Shrike, Talon, and Viper Vertical Spinner and also serve as a team driver.
Our team has registered three robots for Robot Ruckus at Maker Faire Orlando on November 7–8, 2026. I help coordinate the builds and competition preparation while contributing as a driver.
A custom chassis built around a beater-bar assembly, with carbon-fiber-reinforced nylon construction and a polycarbonate top. Designed by students at Embry-Riddle.
View Shrike’s profile (opens in a new tab)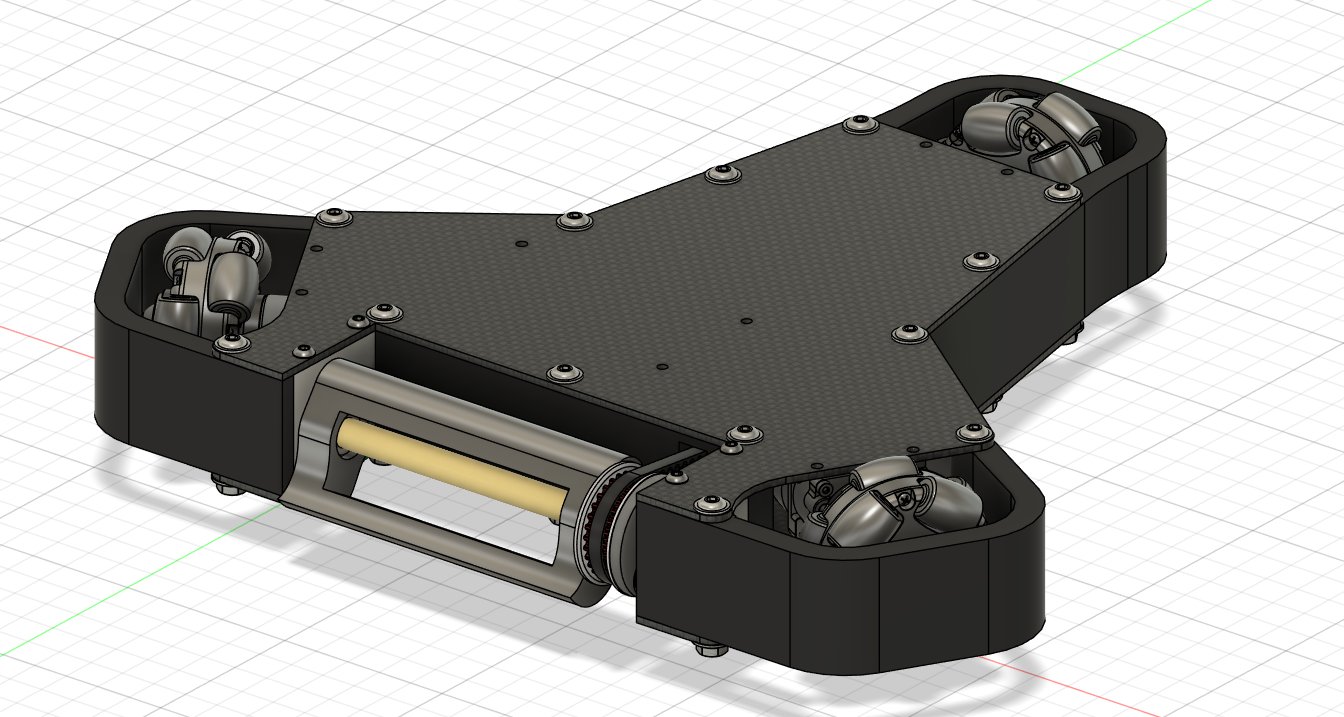
A custom beater-bar spinner designed with speed and maneuverability in mind.
View Talon’s profile (opens in a new tab)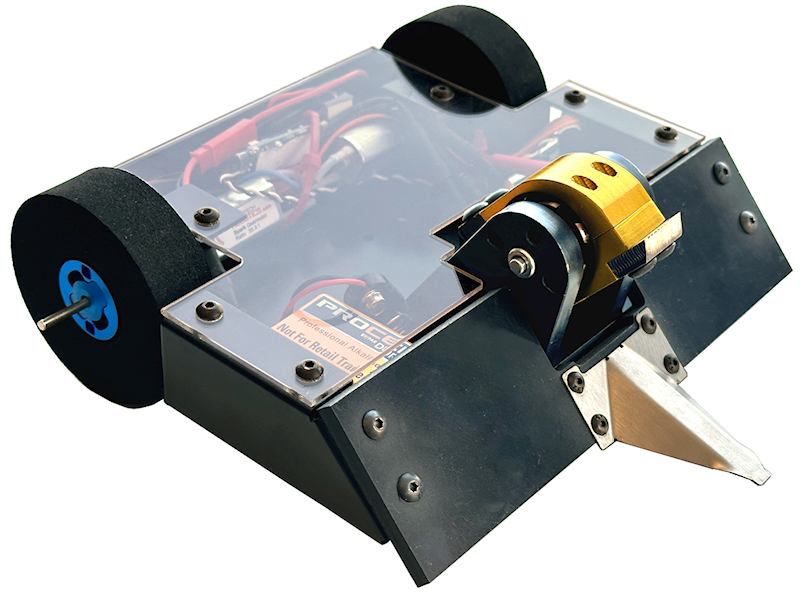
A FingerTech Viper antweight kit fitted with the vertical-spinner add-on, registered in the Gladiator division.
View Viper’s profile (opens in a new tab)Our work includes 1 lb antweight, 3 lb beetleweight, and 30 lb featherweight designs. I evaluate chassis materials, spinner geometry, component budgets, weight estimates, and access for repairs. I use SolidWorks and finite element analysis in chassis and weapon development and collaborate with the team on drive and weapon integration.
I coordinate machining, additive manufacturing, electronics integration, Li-Po battery procedures, and robot assembly.
I lead the development of the team’s safety procedures and testing requirements in coordination with university faculty and Environmental Health and Safety. The designs and testing procedures remain in development. Planning the testing process is part of the engineering work alongside the robots themselves.
Build update · October 2026
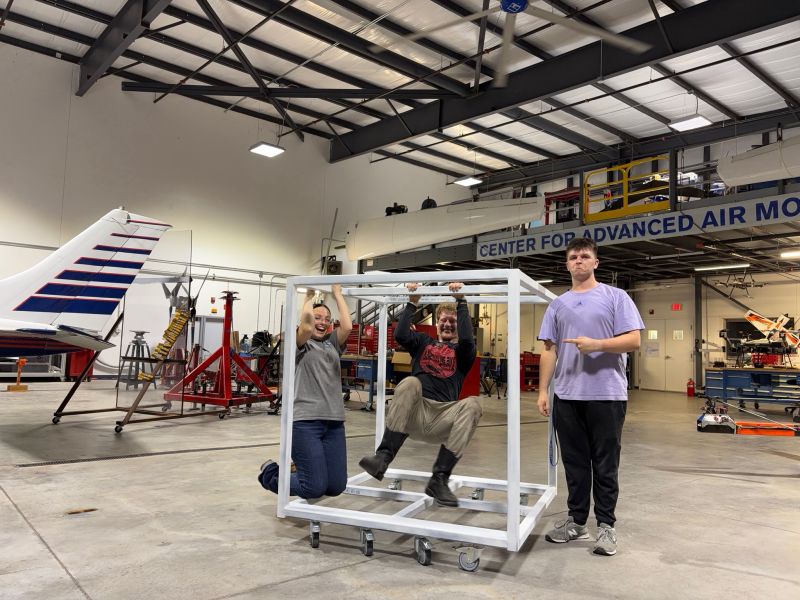
Working with Nicholas Gatto and Madilyn Magno, I helped fabricate a 4 ft × 4 ft × 4 ft mobile steel frame in one ten-hour workday. The build included measuring, cutting, grinding, fitting, welding, painting, and assembly.
The frame is built, with further work needed to complete the enclosure before robot testing.
Read the test-box build storyI also built an automated event tracker to help the team follow competition opportunities and plan travel. It collects event information and posts updates to Discord.
Read about the event tracker