Learning project
Arduino Quadruped
Exploring Arduino servo calibration and coordinated leg movement.
- My role
- Servo calibration & movement-code development
- Objective
- Learn coordinated motion across 12 servo channels
- Tools & methods
- Arduino · Servo control · Joint calibration
- Current result / status
- Assembled; calibration and motion development ongoing
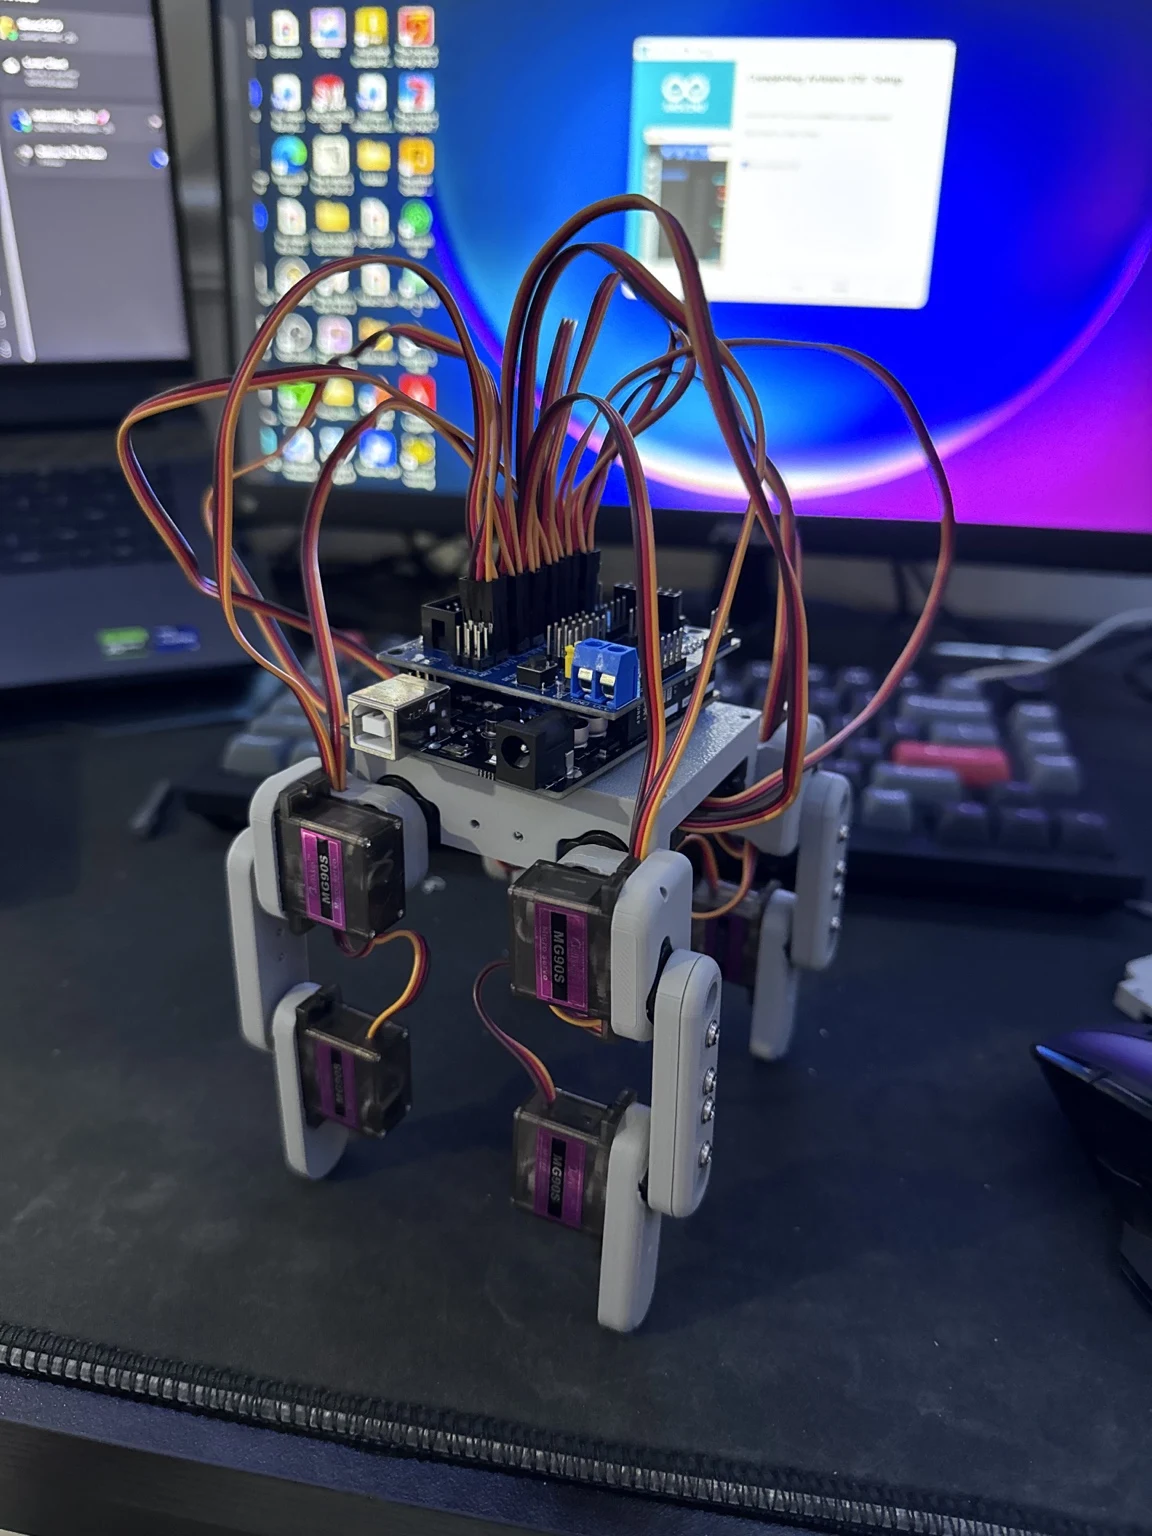
Learning through motion
This Arduino quadruped is a learning project connecting mechanical setup with the code that controls a robot. My focus is servo calibration and coordinated leg movement across 12 servo channels.
Current work
I am assigning servo pins, setting individual joint zero positions, and working with movement code. Each joint needs a useful reference position before the legs can move together consistently.
The project is helping me understand the relationship between joint calibration and robot motion. It remains a learning project; I am not presenting it as a finished autonomous robot.